

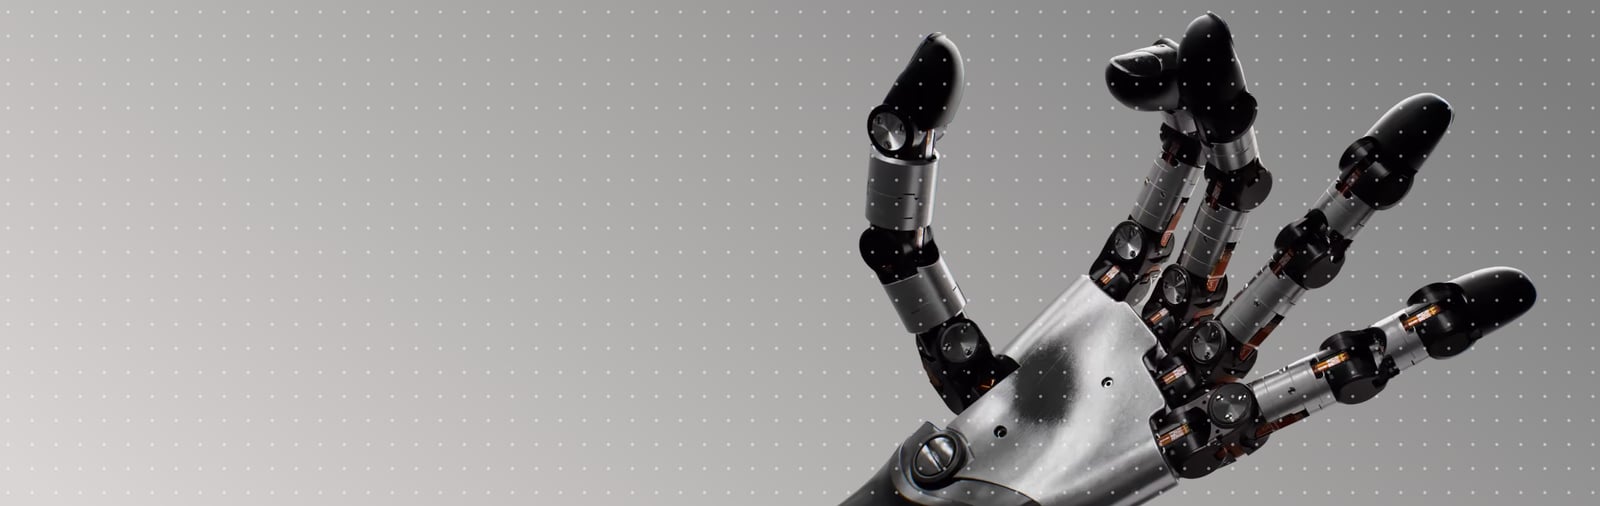
Hardware · DocumentationWuji Hand 2
2.2 BETABiomimetic dexterous hand.20 DOF RJ45 Ethernet Non-tactileRecommended reading path
Follow the stages from version identification and safety preparation through integration and maintenance.Know the Product
Confirm the device version, then review the structure, interfaces, and current capability boundaries.
- Version Identification and Compatibility — Identify the device version and check hardware, firmware, SDK, and CLI compatibility
- Product Introduction — Product overview, specifications, structure, interfaces, status light, and package contents
Before You Power On
Review power, mechanical operation, environmental, and cable requirements before connecting the prototype.
- User Notice — Safety rules and current capability boundaries
Connect and Run
Follow Quick Start for simulation, device connection, the first safe motion, and firmware upgrade.
- Quick Start — Unboxing, software setup, real-device run, first motion, and cross-product teleoperation
- Wuji CLI Device Management — Scan devices, probe connectivity, and select a target without writing code
Integrate and Develop
Move from control conventions and calibration to hardware integration and SDK interfaces.
- Control Guide — Units, MIT control mode, joint table, and parameter safety limits
- Calibration and Configuration — Joint origin, device parameters, IP configuration, and version requirements
- Hardware Integration — Wrist and palm interfaces, frames, models, power, and network
- SDK Interface — Wuji Hand 2 data streams and control interfaces
- SDK Practice — Runnable subscription, control, scanning, and log-export examples
Operations and Appendix
Use maintenance for recovery and routine checks, then use troubleshooting for symptom-based diagnosis.
- Maintenance — Safe stop, fault recovery, serviceable boundaries, checks, and storage
- Troubleshooting — Diagnose discovery, connection, status, joint, and firmware issues
- Appendix — Glossary of control modes, safety actions, and measurement conventions
All pages in this version
Changelog
Version updates and changes across Wuji Hand 2 components
Version Identification and Compatibility
Device version identification and hardware, firmware, SDK, and CLI compatibility
Product Introduction
Specifications, structure, interfaces, status light, and package contents
User Notice
Power, operation, environment, cable protection, and capability boundaries
Quick Start
Simulation, real-device run, first motion, shutdown, and firmware upgrade
Control Guide
Units, MIT control mode, joint table, and parameter safety limits
Calibration
Joint origin, device parameters, IP configuration, and version requirements
Hardware Integration
Mounting interfaces, frames, models, power, and network configuration
SDK Interface
Data streams, joint control, device operations, and diagnostics
SDK Practice
Runnable subscription, control, scanning, and log-export examples
Maintenance
Fault recovery, serviceable boundaries, checks, and storage
Troubleshooting
Symptom-based device and runtime diagnosis
Appendix
Control, safety, and measurement terminology