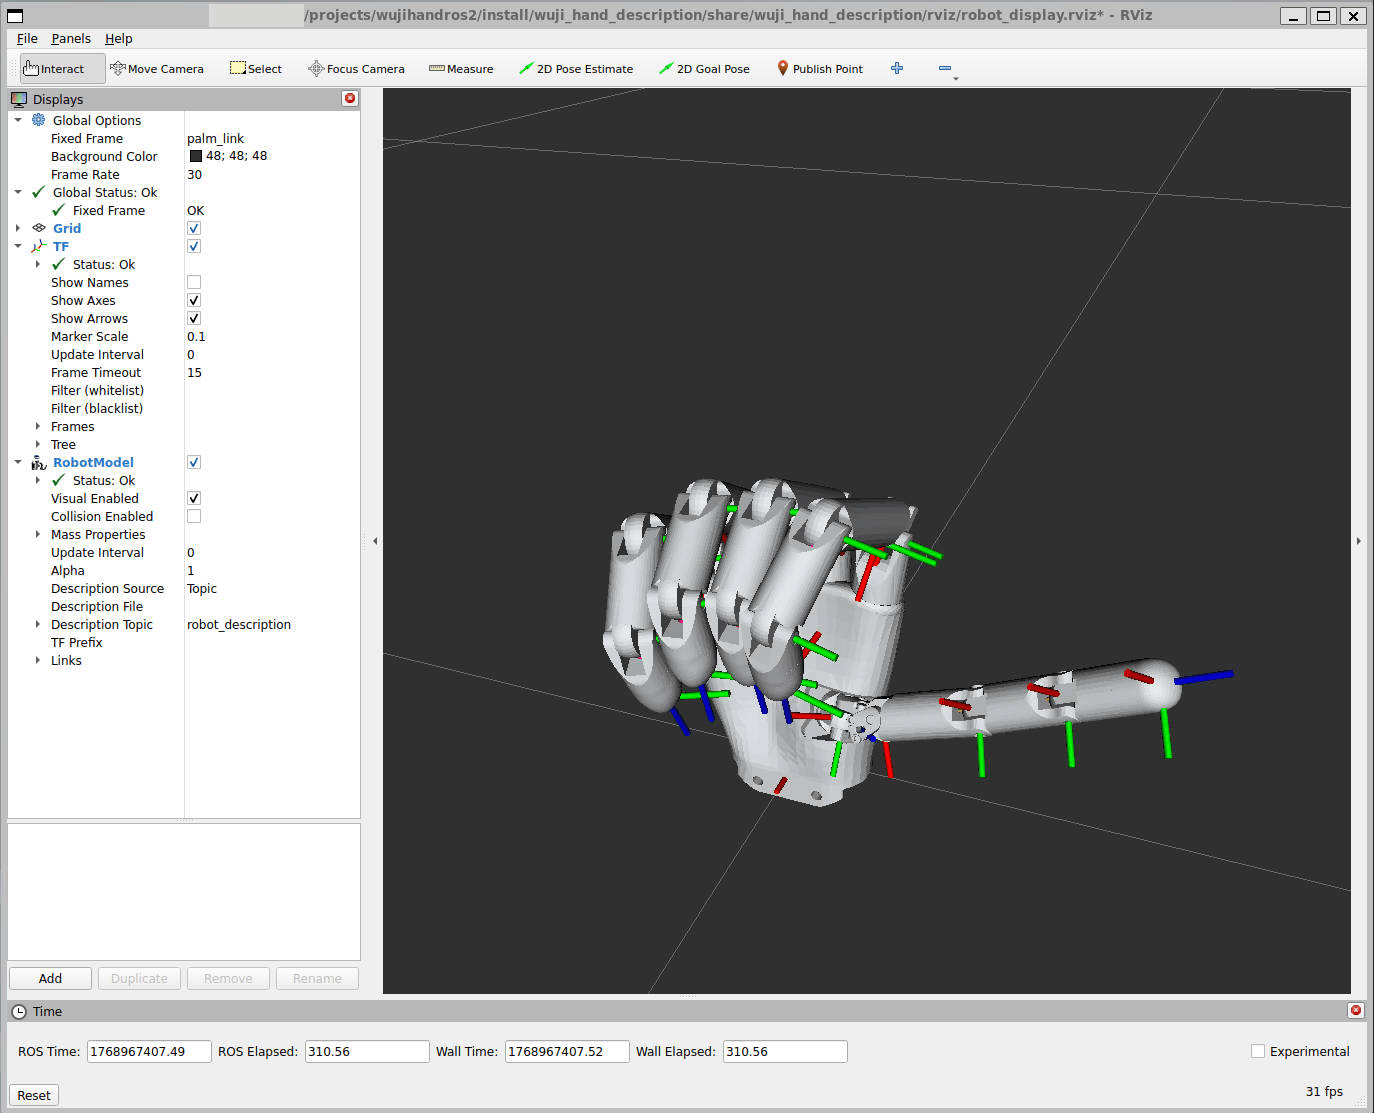
Launch the Driver
Verify Operation
Open a new terminal and check the joint states:Run Demo
When multiple hands are connected, specify the target hand with
--ros-args -p hand_name:=<hand-name>. See Multi-hand Configuration for details.Launch RViz Visualization