> ## Documentation Index
> Fetch the complete documentation index at: https://docs.wuji.tech/llms.txt
> Use this file to discover all available pages before exploring further.
# Appendix
## Algorithm Principles
**Optimization Formula**
The system uses `AdaptiveOptimizerAnalytical` optimizer with Huber loss + hand-written analytical gradients + NLopt SLSQP:
Where $q_{\mathrm{prev}}$ is the joint angles from the previous frame, and $\lambda$ is `norm_delta` (velocity regularization weight).
**Adaptive Blending**
The algorithm automatically switches optimization strategies based on finger pinch state:
* $d_i$: Distance from the thumb to the tip of finger $i$
* $d_1$, $d_2$: Pinch thresholds (default: 2.0 cm, 4.0 cm)
**TipDirVec Mode**: Optimizes fingertip position and direction, suitable for fine pinch actions
**FullHandVec Mode**: Optimizes full hand pose, suitable for open and grasping actions
## Troubleshooting
**Q: pinocchio installation fails?**
If installing from a PyPI mirror fails, use the official source. Note: The package name on PyPI is `pin` (not `pinocchio`):
```bash theme={null}
pip install pin==3.8.0 -i https://pypi.org/simple
```
**Q: MuJoCo window not displaying on macOS?**
Use `mjpython` instead of `python` to run simulation scripts on macOS:
```bash theme={null}
mjpython teleop_sim.py --play data/avp1.pkl --hand left
```
**Q: Video mode says `mediapipe` or `opencv-python` is missing?**
Install the video dependencies:
```bash theme={null}
pip install -e ".[video]"
```
This will install the `mediapipe` and `opencv-python` packages required for video mode.
**Q: RealSense mode cannot start or reports that `pyrealsense2` is missing?**
Install the RealSense extra dependencies:
```bash theme={null}
pip install -e ".[realsense]"
```
Also make sure an Intel RealSense device is connected and not occupied by another application.
**Q: RealSense reports `device is busy`?**
This usually means the camera is already being used by another tool or process. Close the other application and try again.
**Q: `--show-video` causes lag?**
`--show-video` is intended for debugging and adds extra rendering overhead. Disable it when you care more about runtime performance than visual inspection.
## Custom Input Devices
Want to integrate your own hand input device — a glove, XR headset, or mocap system? Convert your device data into the unified 21-point hand keypoint format, and the retargeting, simulation, and real-hardware pipelines all reuse without change. No algorithm edits needed.
### The Input Interface
Every input device implements one method:
```python theme={null}
def get_fingers_data(self) -> dict:
return {
"left_fingers": np.ndarray, # shape (21, 3), meters
"right_fingers": np.ndarray, # shape (21, 3), meters
}
```
Conventions:
* Return an all-zero array `np.zeros((21, 3))` when a hand is unavailable.
* Order the 21 points to match the MediaPipe hand landmark definition (see the table below).
* Use the wrist (point 0) as the coordinate origin.
Once this interface aligns, `teleop_sim.py`, `teleop_real.py`, and `tuning_tool.py` all reuse directly.
### Integration Steps
1. **Create the device class.** Add `my_device.py` under `example/input_devices/`, subclass `InputDeviceBase`, and implement `get_fingers_data()`. Reference `visionpro.py` (live TCP), `mediapipe_replay.py` (pkl replay), or `video_mediapipe.py` (video plus MediaPipe).
2. **Register the device.** Add `"my_device": lambda: MyDevice(...)` to the `device_map` in both `teleop_sim.py` and `teleop_real.py`, and add `"my_device"` to the `--input` choices. Keep both files consistent.
3. **Prepare a config.** Copy an existing YAML (such as `config/adaptive_analytical_avp.yaml`) and adjust `mediapipe_rotation`, `segment_scaling`, `lp_alpha`, `norm_delta`, and `pinch_thresholds` for your device.
### Debugging Order
Follow the stages in order — don't skip ahead:
1. **Record a pkl sample first**, before connecting a live stream. A recorded sample makes problems reproducible and separates data issues from algorithm issues.
2. **Inspect the skeleton overlay** with `tuning_tool.py --play`. Confirm the pose is correct, the left and right hands aren't swapped, and the three skeleton layers track each other.
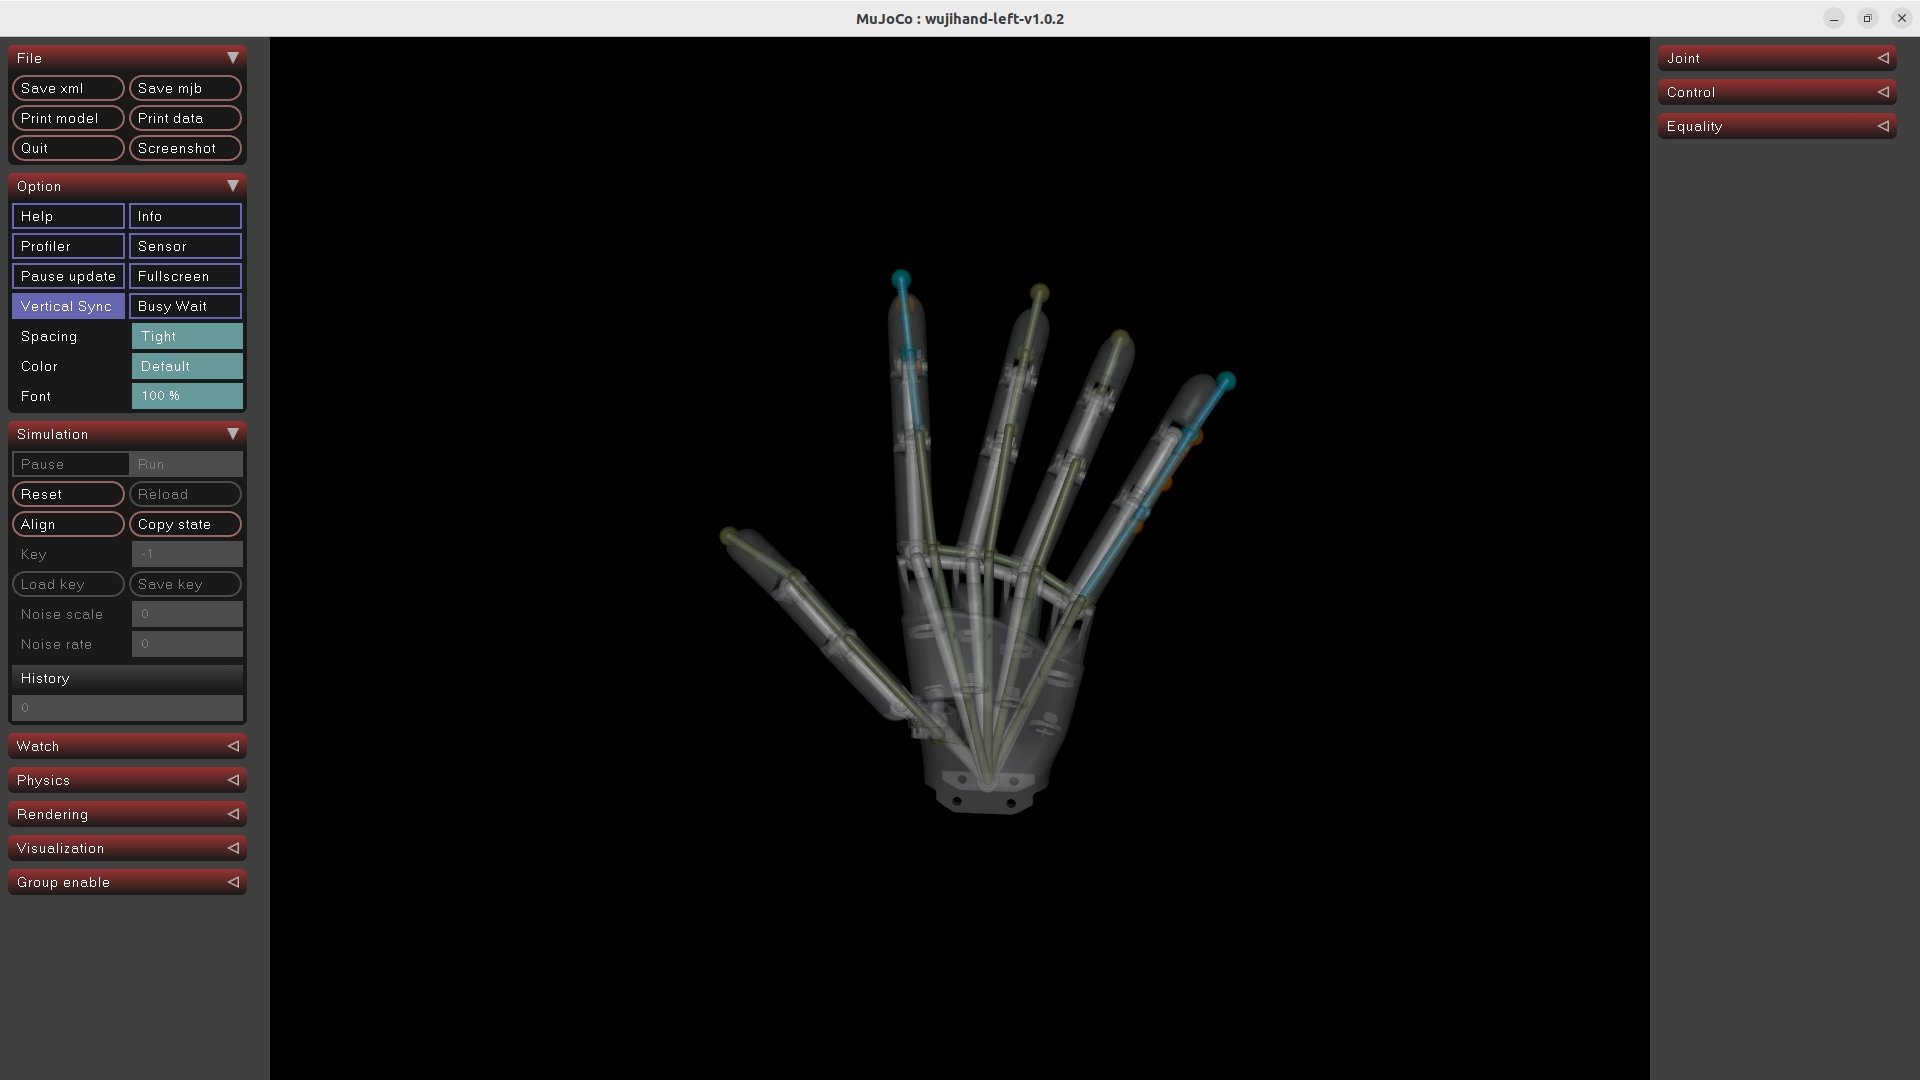 | Color | Meaning |
| - | - |
| Orange | Raw input keypoints |
| Cyan | Target after `segment_scaling` adjustment |
| White | Robot FK result (retargeting output) |
3. **Run the MuJoCo simulation** with `teleop_sim.py --play`. Verify the motion is smooth and holds up at extreme poses.
4. **Connect the live stream and real hardware last**, after the simulation passes.
### MediaPipe 21-Point Order
```text theme={null}
Index Joint name
0 Wrist (coordinate origin)
1 Thumb CMC 2 Thumb MCP 3 Thumb IP 4 Thumb TIP
5 Index MCP 6 Index PIP 7 Index DIP 8 Index TIP
9 Middle MCP 10 Middle PIP 11 Middle DIP 12 Middle TIP
13 Ring MCP 14 Ring PIP 15 Ring DIP 16 Ring TIP
17 Pinky MCP 18 Pinky PIP 19 Pinky DIP 20 Pinky TIP
```
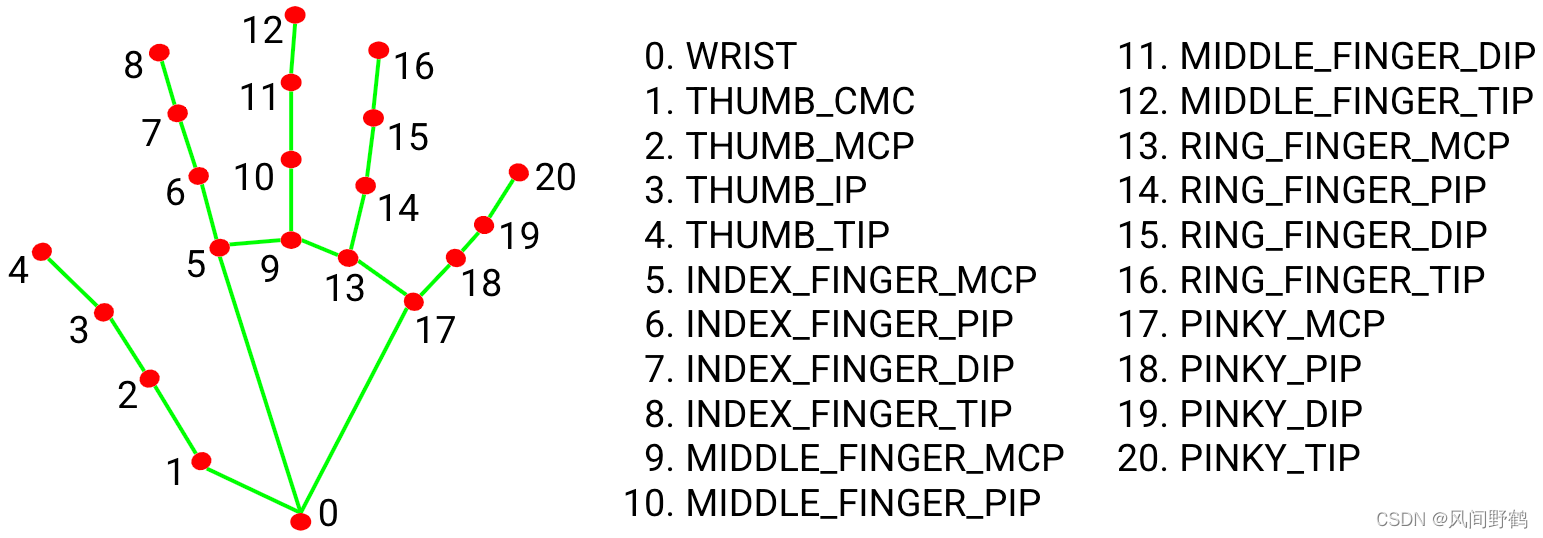 If your device uses a different skeleton order, reorder in `_convert()`:
```python theme={null}
# Device-native indices, in MediaPipe point order
DEVICE_TO_MEDIAPIPE = [0, 4, 3, 2, 1, 8, 7, 6, 5, ...]
kp_mediapipe = kp_device[DEVICE_TO_MEDIAPIPE]
```
## Related Resources
* **GitHub Repository**: [wuji-technology/wuji-retargeting](https://github.com/wuji-technology/wuji-retargeting)
* **Wuji Hand SDK**: [wuji-technology/wujihandpy](https://github.com/wuji-technology/wujihandpy)
* **Vision Pro Streaming**: [VisionProTeleop](https://github.com/Improbable-AI/VisionProTeleop)
* **Technical Support**: [support@wuji.tech](mailto:support@wuji.tech)
This documentation is built and hosted on [Mintlify](https://mintlify.com), a developer documentation platform.