> ## Documentation Index
> Fetch the complete documentation index at: https://docs.wuji.tech/llms.txt
> Use this file to discover all available pages before exploring further.
# Introduction
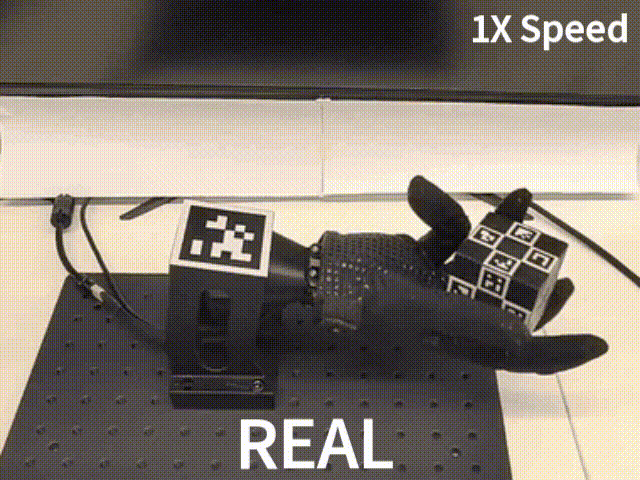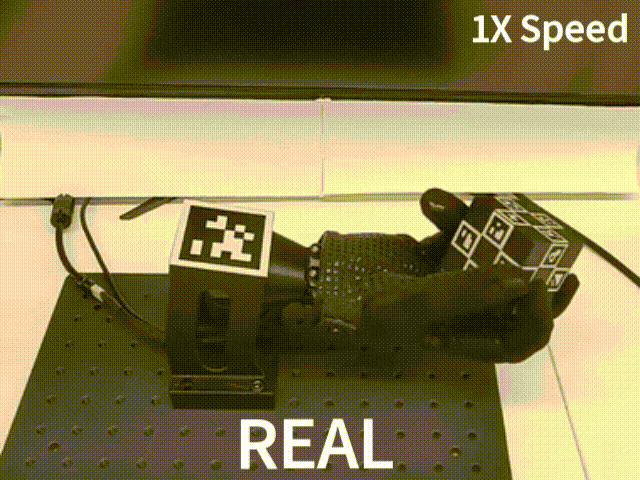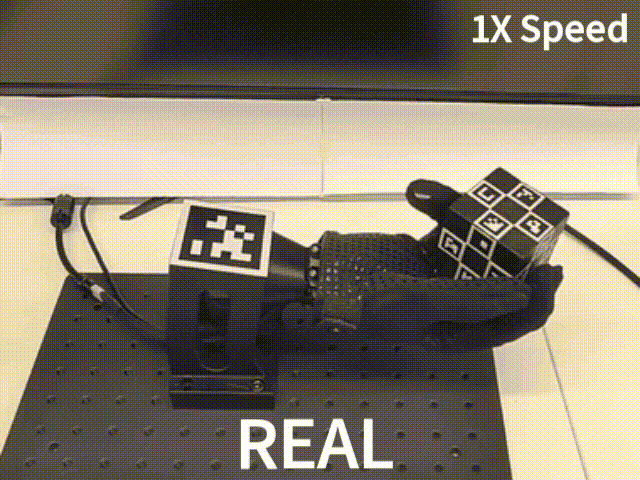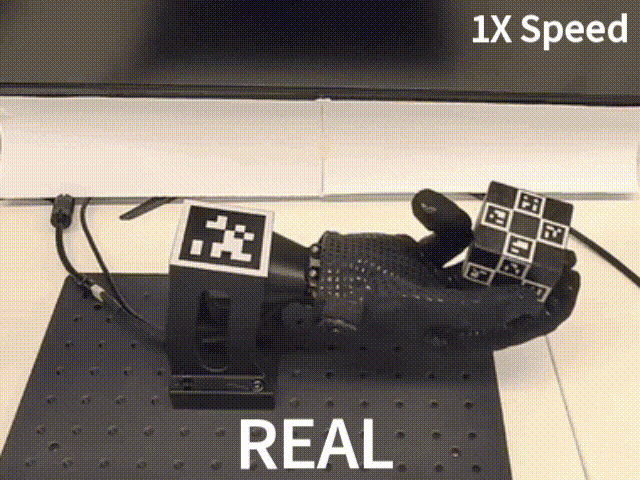
> In-hand cube reorientation on the Wuji Hand — PPO policies trained in mjlab that cover the full SO(3) goal space, with a sim-to-real bridge for closed-loop deployment on the physical hand.
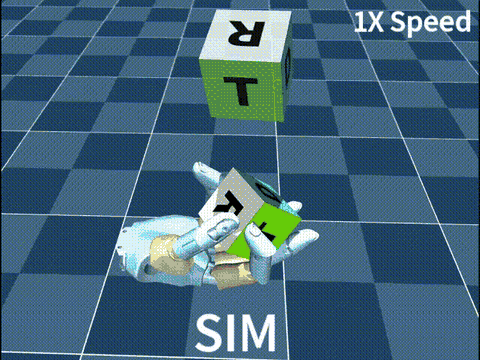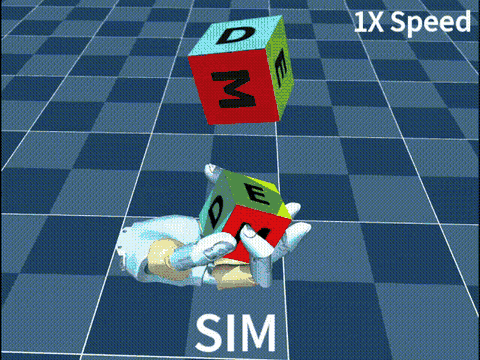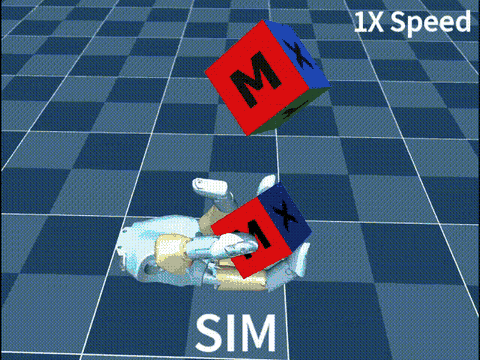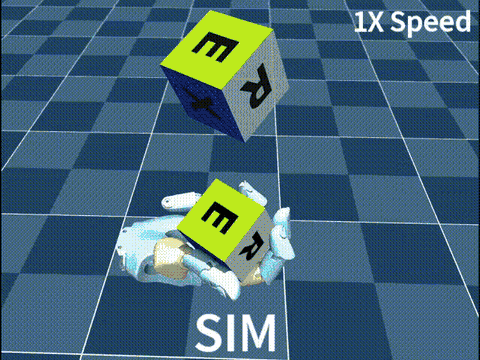
wuji-mjlab is an in-hand cube reorientation reinforcement learning project for the Wuji Hand. It trains PPO policies in [mjlab](https://github.com/mujocolab/mjlab) that cover the full SO(3) goal space, then deploys them on the physical hand through a sim-to-real bridge. The project ships pretrained checkpoints, deployment scripts, and hardware guides so you can reproduce the demo end to end.
This release targets the Wuji Hand. The deploy bridge wraps the Wuji Hand SDK and expects the matching firmware revision.
## Task
The project centers on one task, with two training configurations.
| Robot | Task ID | Pretrained checkpoint | Demo |
| - | - | - | - |
| Wuji Hand | `WujiHand_Reorient` | [Latest release assets](https://github.com/wuji-technology/wuji-mjlab/releases/latest) | Sim and real demos above |
The policy holds a cube in a downward-facing hand, receives a target orientation in the palm frame, and rotates the cube in place until its orientation matches the goal within a hold window, without dropping it.
## What You Get
* A calibrated pipeline that runs the trained ONNX policy on real Wuji Hand hardware
* Pretrained checkpoints and released policy assets, so you can deploy without training
* A 3D-printed ArUco-tagged cube, wrist AprilTag world frame, and camera calibration workflow
* Two training configurations: a release config that reproduces the demo, and a lower-VRAM variant
## Get the Released Assets
Pull the pretrained checkpoint and CAD bundle from the latest release:
```bash theme={null}
# Requires the GitHub CLI (https://cli.github.com). The glob keeps this
# command working unchanged across future release tags.
gh release download --repo wuji-technology/wuji-mjlab --pattern '*-assets.zip'
unzip wuji-mjlab-*-assets.zip
mv wuji-mjlab-*-assets release-assets
```
Without the `gh` CLI, open the [latest release page](https://github.com/wuji-technology/wuji-mjlab/releases/latest), download the `wuji-mjlab-v*-assets.zip` attachment by hand, then run the same `unzip` and `mv` pair.
This documentation is built and hosted on [Mintlify](https://mintlify.com), a developer documentation platform.