

This release targets the Wuji Hand. The deploy bridge wraps the Wuji Hand SDK and expects the matching firmware revision.
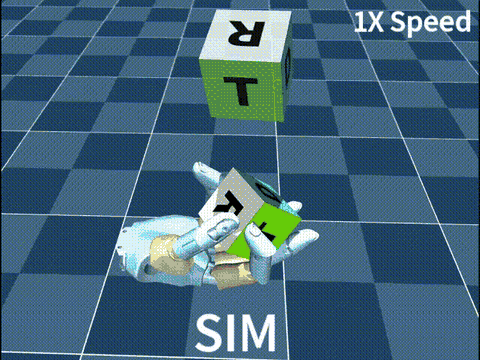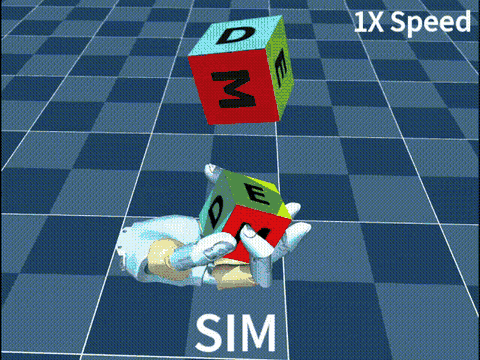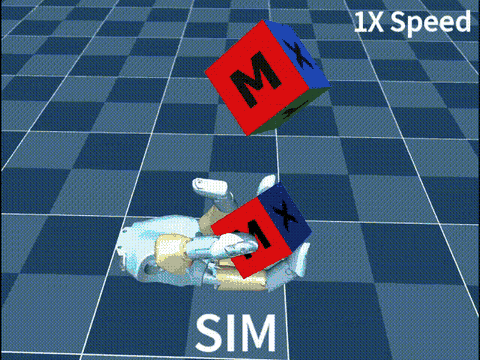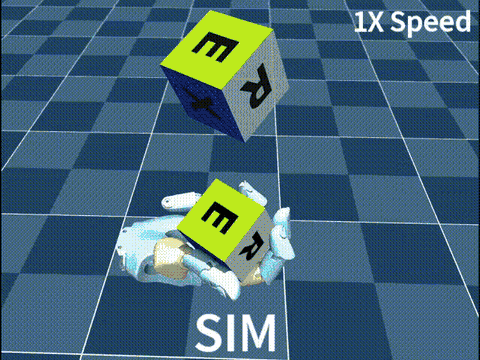
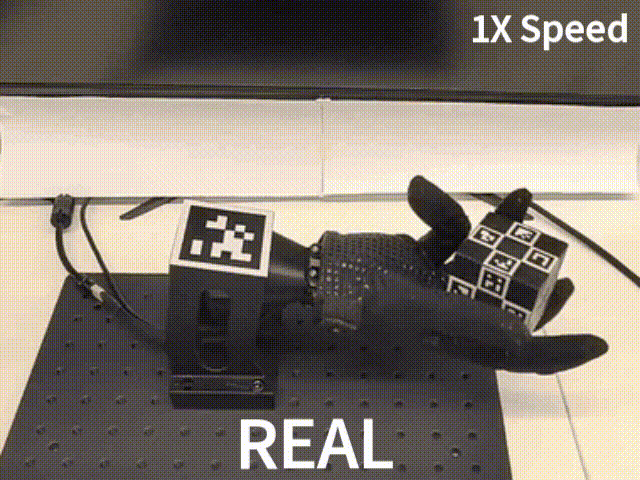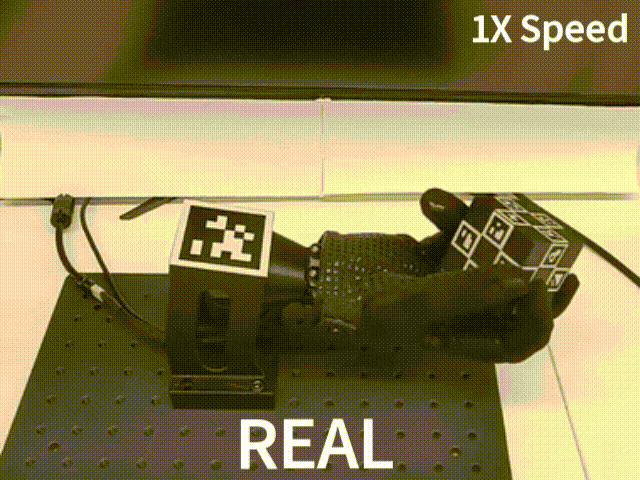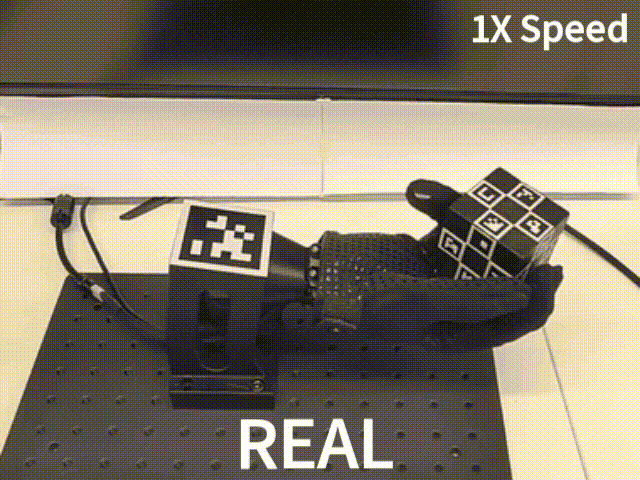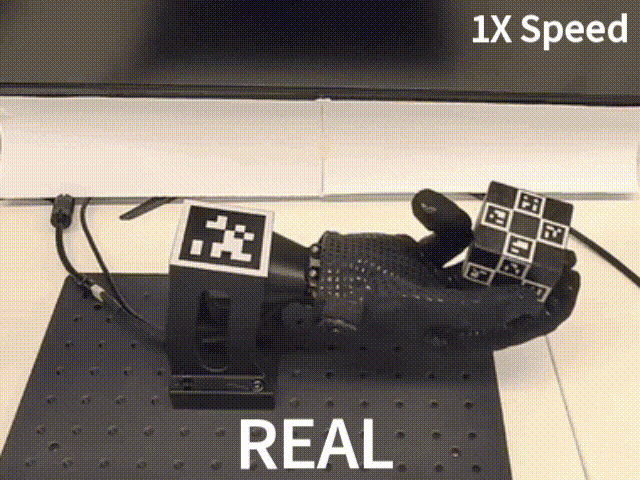
Task
The project centers on one task, with two training configurations.
The policy holds a cube in a downward-facing hand, receives a target orientation in the palm frame, and rotates the cube in place until its orientation matches the goal within a hold window, without dropping it.
What You Get
- A calibrated pipeline that runs the trained ONNX policy on real Wuji Hand hardware
- Pretrained checkpoints and released policy assets, so you can deploy without training
- A 3D-printed ArUco-tagged cube, wrist AprilTag world frame, and camera calibration workflow
- Two training configurations: a release config that reproduces the demo, and a lower-VRAM variant
Get the Released Assets
Pull the pretrained checkpoint and CAD bundle from the latest release:gh CLI, open the latest release page, download the wuji-mjlab-v*-assets.zip attachment by hand, then run the same unzip and mv pair.