

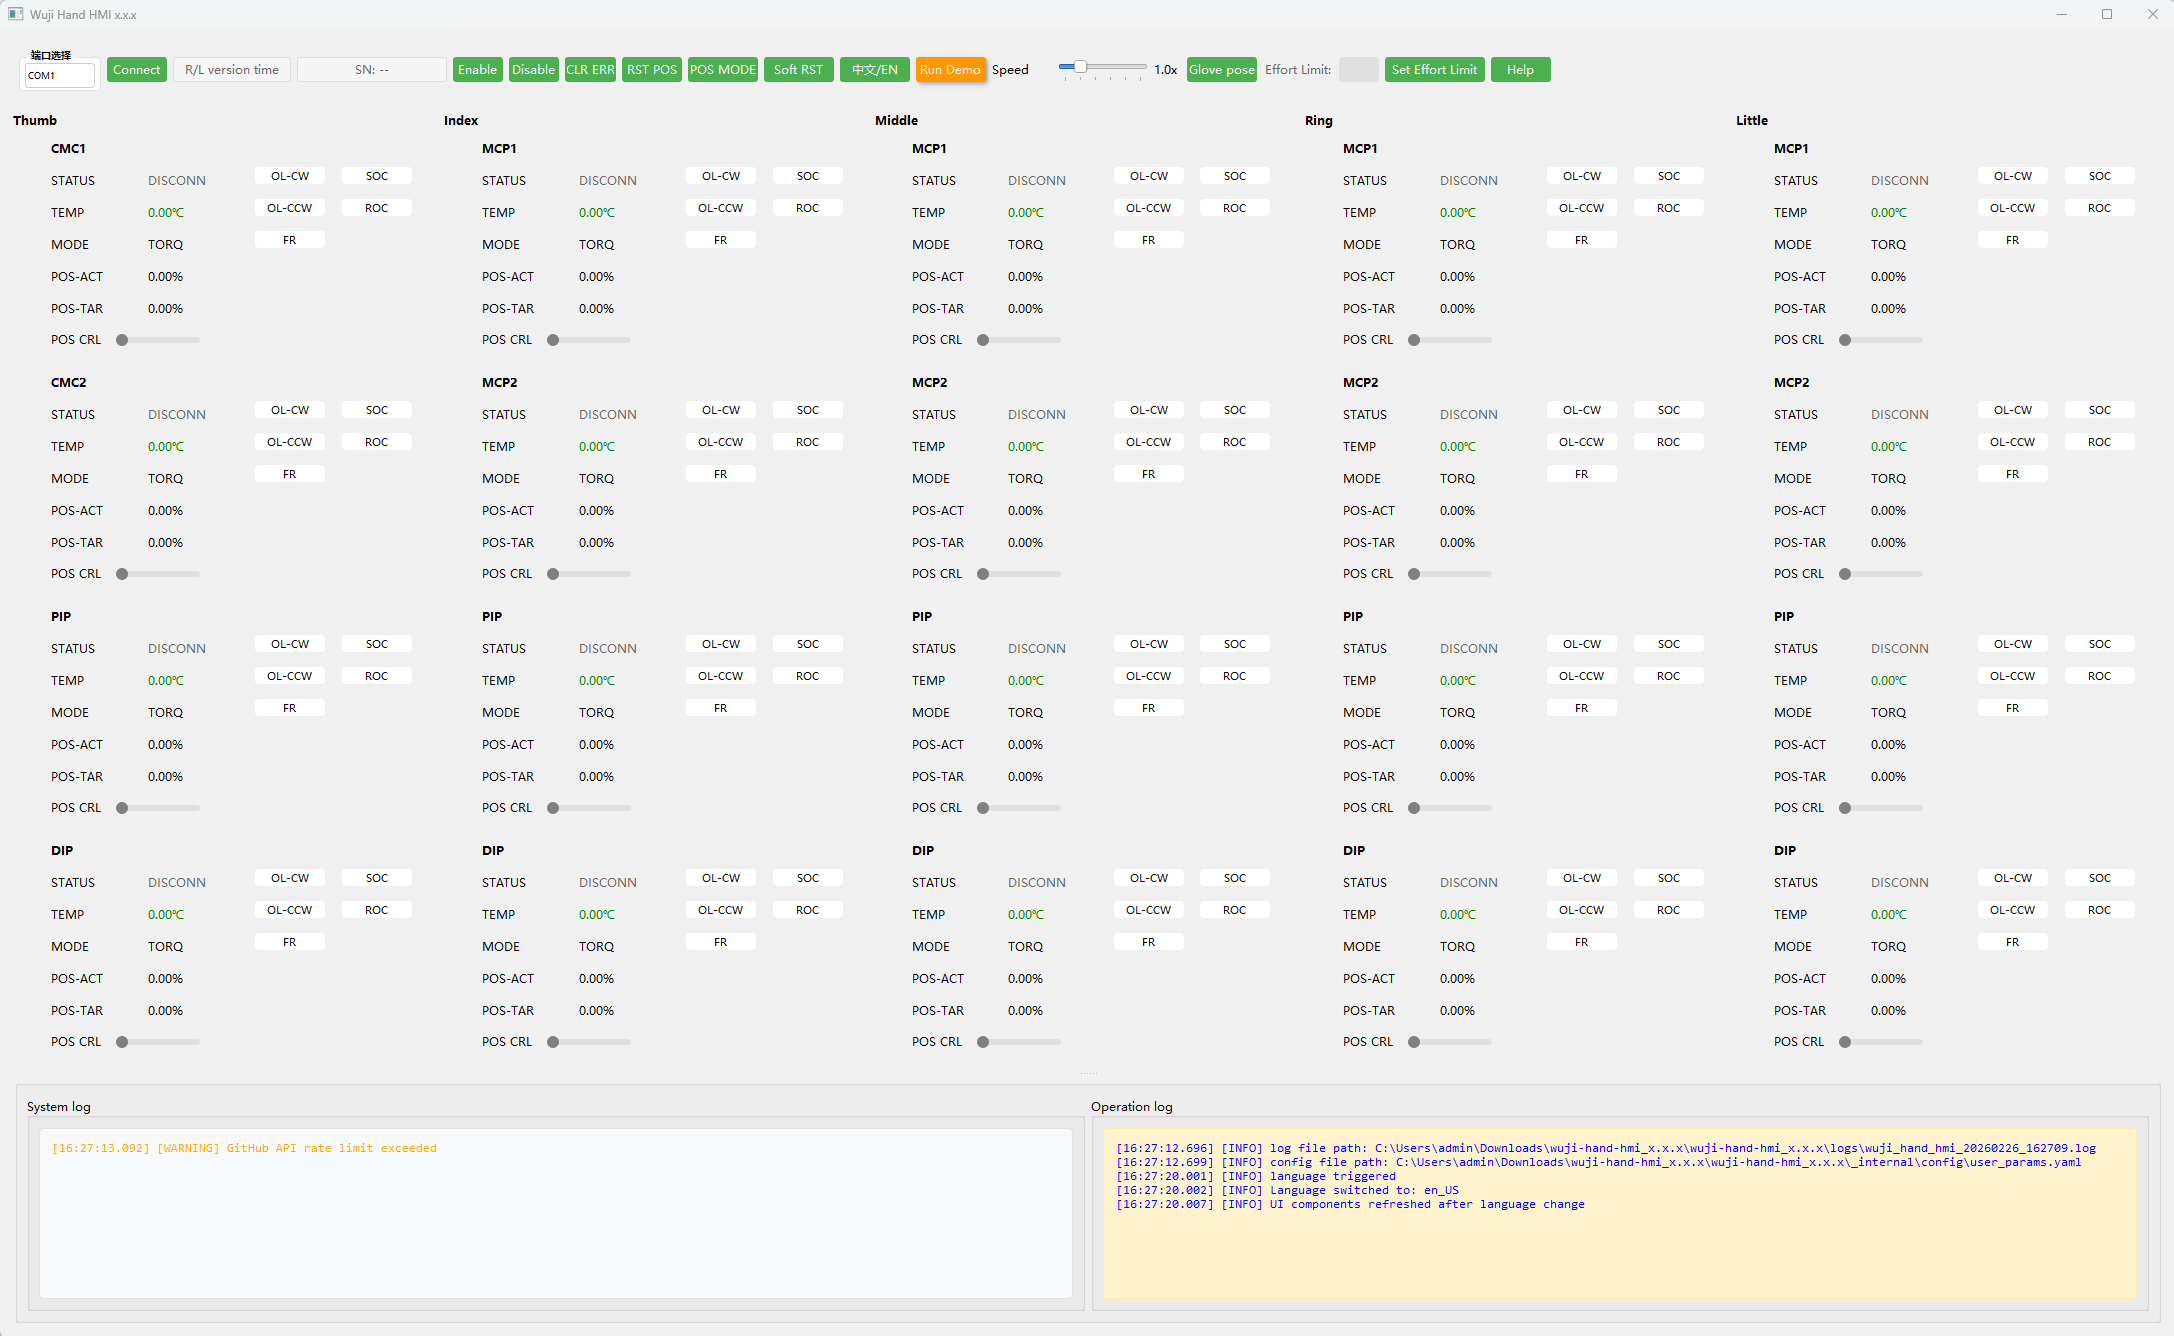
Global Panel
The Global Panel is for whole-hand operations and status viewing. It operates the entire hand, with feedback from the spinal board.
| Name | Description |
|---|---|
| Port selection | The Linux HMI auto-filters available ports. The Windows HMI doesn’t filter ports automatically. Launch the HMI first, then connect the hand. Check the Log Panel Operation Log for [INFO] New ports: ['COM XX'] to identify the Wuji Hand port. |
| Connect / Disconn | Choose the correct port and click Connect. Click Disconn to end the session. |
| Spinal board status | Displays: Left/Right hand, system firmware version, online time, e.g. Left 1.2.0 24m59s. |
| SN | Displays the device serial number. |
| Enable | Click Enable to power all joint motors. Motor status becomes RUN. |
| Disable | Click Disable to de-energize all joint motors. Motor status becomes READY. |
| CLR ERR | If WARNING/ERROR/FATAL appears, click CLR ERR first, then try enabling again after recovery. |
| POS MODE / RST POS | Click POS MODE to set motor mode to RT_FCL. While enabled, click RST POS to return the hand to the zero pose. |
| Soft RST | Restart the driver boards. During restart, motor status briefly shows DISCONN. After completion, motor status returns to READY. |
| 中文 / EN | Toggle UI language between Chinese and English. |
| Run Demo | Click Run Demo to play a preset motion sequence for quickly verifying communication and basic motion. |
| Speed | Controls the demo playback speed multiplier. Drag the slider to adjust. Range 0.5x–3.0x, default 1.0x. |
| Glove pose | Click Glove pose to switch the hand to a posture that facilitates removing and installing soft components and gloves. |
| Effort Limit | Effort limit input field for entering the target value, used with the Set Effort Limit button. |
| Set Effort Limit | Sets the maximum effort output allowed for joints. Range 0–3.5 (A), default 1.5 (A). Enter a value in the input field and click Set Effort Limit. What is Effort?Effort is the actuation value in current space, filtered before output. It is not the actual measured current—think of it as relative actuation strength, useful for load monitoring and collision detection. |
| Help | Click Help to open this documentation page. |
Single-Axis Panel
The Single-Axis Panel is for single-joint operations and status viewing. It operates individual joint axes, with feedback from the driver board.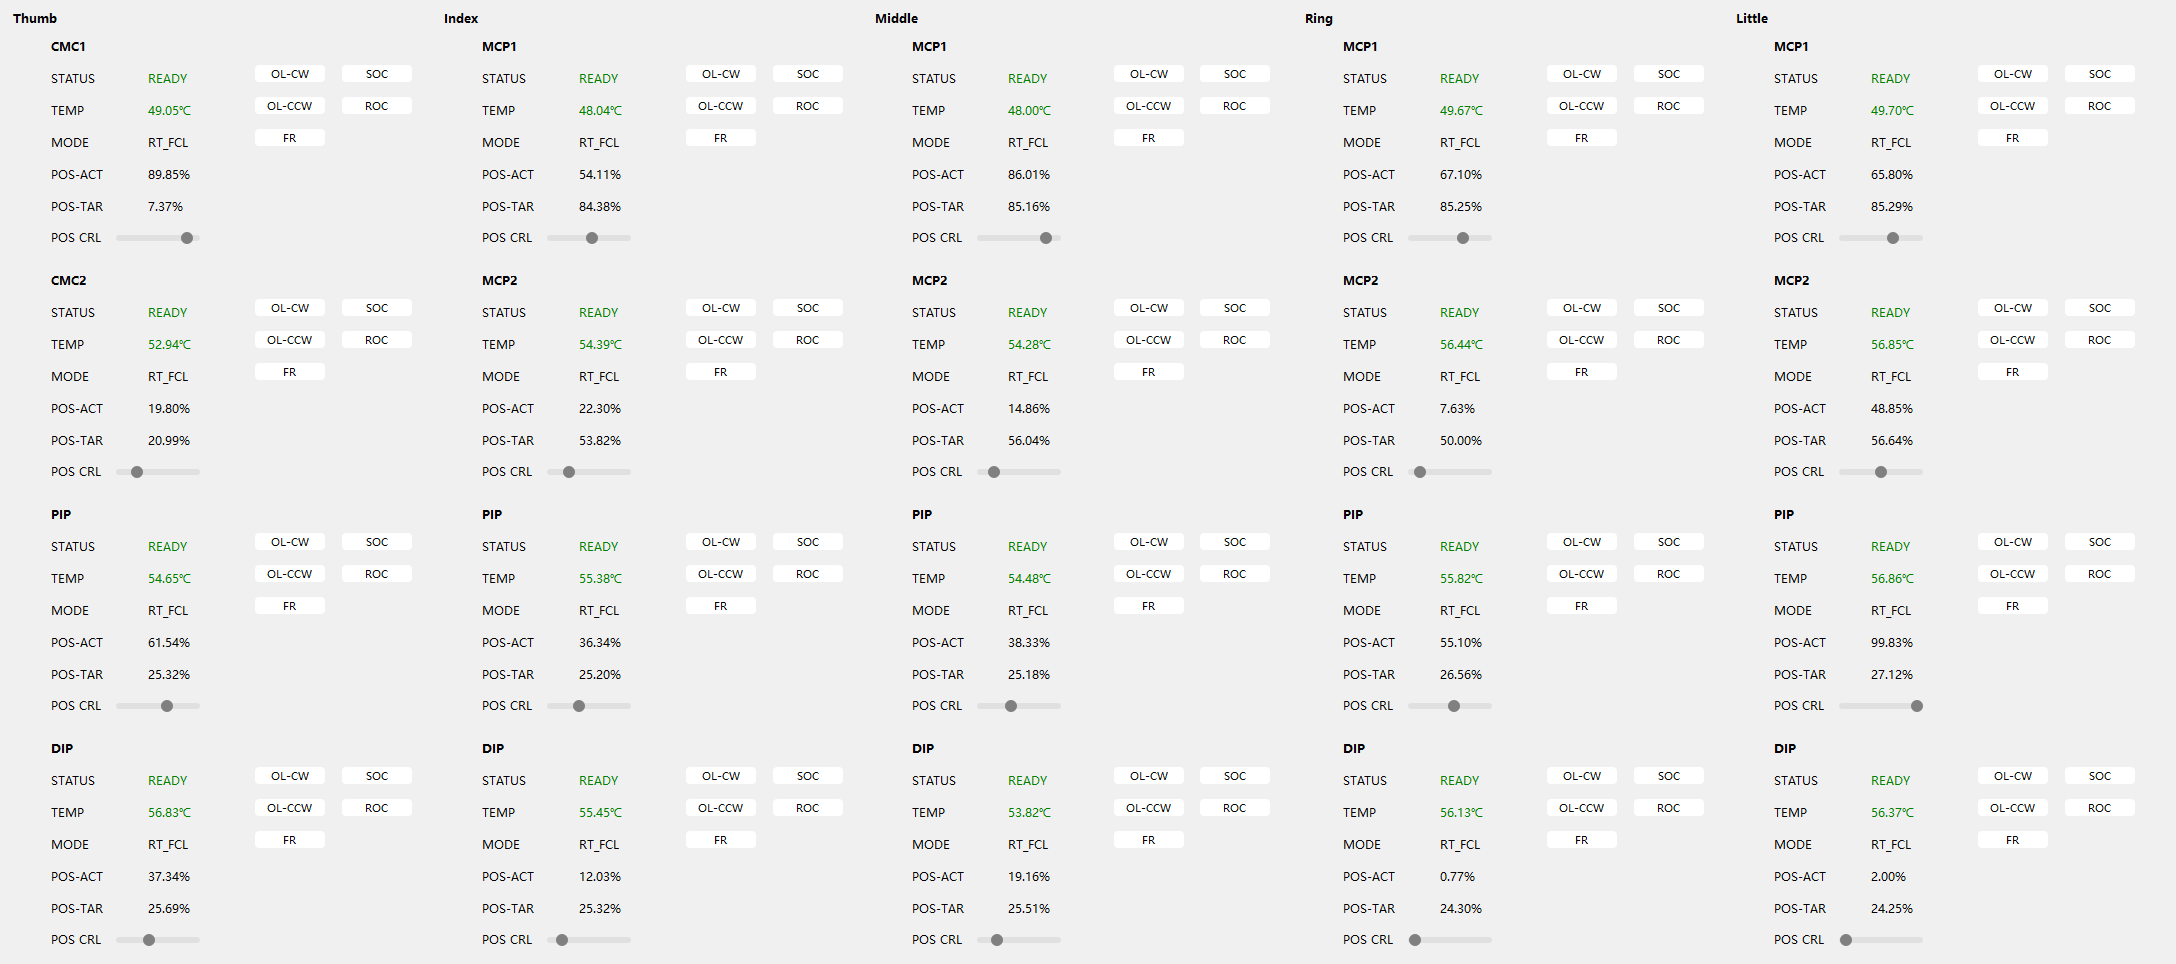
| Name | Description |
|---|---|
| Joint | Joint name. |
| STATUS |
|
| TEMP | Displays the current motor temperature. |
| MODE | Displays the current control mode, e.g. RT_FCL. |
| POS-ACT | Displays the position feedback as a percentage within the factory-calibrated travel range. |
| POS-TAR | Displays the desired position as a percentage within the factory-calibrated travel range. |
| POS CRL | When MODE is RT_FCL and STATUS is RUN, drag the slider to set the target position. |
| OL-CW / OL-CCW | Open-loop motion corresponding to clockwise/counterclockwise polarities. Press and hold OL-CW or OL-CCW to rotate the motor in one direction. |
| FR | Click FR to open the factory reset dialog: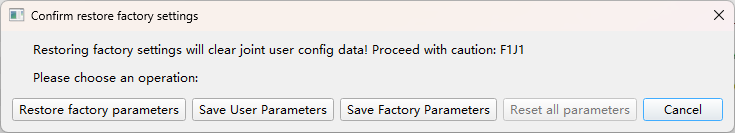
After restoring to factory settings, click Soft RST in the Global Panel for the changes to take effect.
|
| SOC / ROC |
|
Log Panel
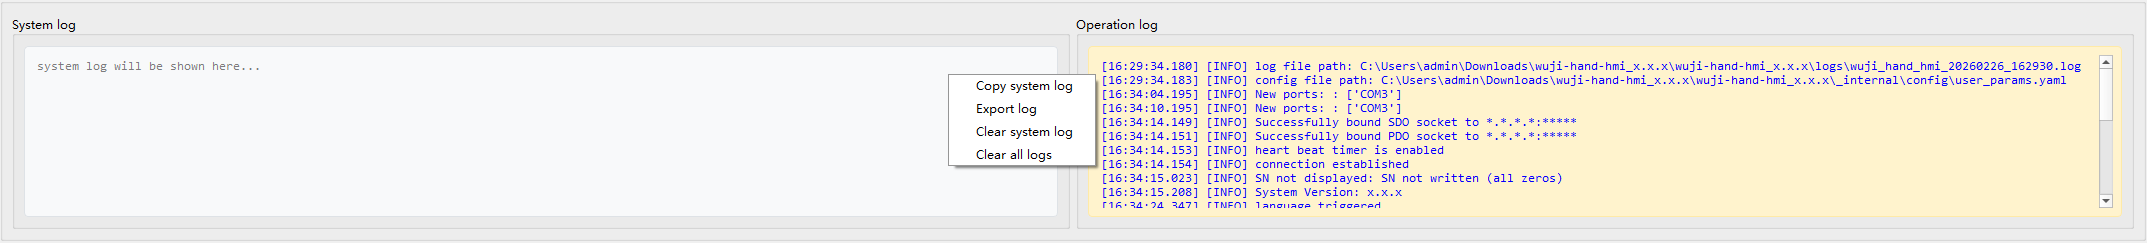
- Copy system log / Copy operation log: copy selected log content to the clipboard.
- Export log: package both system and operation logs for troubleshooting.
- Clear system log / Clear operation log: clear the corresponding log area.
- Clear all logs: clear both system and operation logs.