> ## Documentation Index
> Fetch the complete documentation index at: https://docs.wuji.tech/llms.txt
> Use this file to discover all available pages before exploring further.

# Product Introduction

## Overview

Wuji Glove is an intelligent data glove designed for robot teleoperation and human-computer interaction research. It captures tactile perception and posture data from the human hand in real time.

| Core Function | Specification | Output |
| - | - | - |
| Tactile Sensing | 24 × 31 pressure sensor matrix (526 active points) | 120 FPS, normalized pressure values 0-1 |
| Pose Tracking | 5 EMF modules | 120 Hz, finger 3D position and pose |
| IMU | 800 Hz high-frequency sampling | Acceleration + Angular velocity |

**Typical Application Scenarios:**

* Robot dexterous hand teleoperation
* Tactile data collection and research
* Human-computer interaction experiments
* VR/AR gesture input

## Specifications

### Glove parameters

Detailed technical specifications for the Wuji Glove:

<table>
  <thead>
    <tr>
      <th>Category</th>
      <th>Parameter</th>
      <th>Value</th>
    </tr>
  </thead>

  <tbody>
    <tr>
      <td rowSpan="5">Dimensions & Weight</td>
      <td>Glove Size (L × W)</td>
      <td>215 × 195 mm</td>
    </tr>

    <tr>
      <td>Thickness (Fabric / With Structure)</td>
      <td>6.55 mm / 35 mm</td>
    </tr>

    <tr>
      <td>Total Length (With Cable)</td>
      <td>340 mm</td>
    </tr>

    <tr>
      <td>Glove Net Weight</td>
      <td>67.5 g</td>
    </tr>

    <tr>
      <td>Total Weight (With Cable)</td>
      <td>192.6 g</td>
    </tr>

    <tr>
      <td rowSpan="10">Tactile Sensor</td>
      <td>Sensor Type</td>
      <td>Pressure Sensor Matrix</td>
    </tr>

    <tr>
      <td>Array Resolution</td>
      <td>24 × 31 Pressure Sensor Matrix (526 Active Points)</td>
    </tr>

    <tr>
      <td>Output Rate</td>
      <td>120 FPS</td>
    </tr>

    <tr>
      <td>Pressure Range</td>
      <td>0 – 20 N</td>
    </tr>

    <tr>
      <td>Pressure Resolution</td>
      <td>0.1 N</td>
    </tr>

    <tr>
      <td>Spatial Resolution</td>
      <td>4 mm</td>
    </tr>

    <tr>
      <td>Coverage</td>
      <td>Full Palmar Side</td>
    </tr>

    <tr>
      <td>Repeatability</td>
      <td>±6%</td>
    </tr>

    <tr>
      <td>Press Life</td>
      <td>100,000+</td>
    </tr>

    <tr>
      <td>Flex Life</td>
      <td>100,000+</td>
    </tr>

    <tr>
      <td rowSpan="3">Spatial Tracking</td>
      <td>EMF Modules</td>
      <td>5 EMF Modules, 6 DOF Each</td>
    </tr>

    <tr>
      <td>Position Accuracy</td>
      <td>≤ 2 mm RMS</td>
    </tr>

    <tr>
      <td>Orientation Accuracy</td>
      <td>\< 5° RMS</td>
    </tr>

    <tr>
      <td rowSpan="4">IMU</td>
      <td>Count / Type</td>
      <td>1 × 6-Axis IMU (Dorsum)</td>
    </tr>

    <tr>
      <td>Output Rate</td>
      <td>800 Hz</td>
    </tr>

    <tr>
      <td>Accelerometer Range</td>
      <td>±16 g</td>
    </tr>

    <tr>
      <td>Gyroscope Range</td>
      <td>±2000 °/s</td>
    </tr>

    <tr>
      <td rowSpan="3">Power & Communication</td>
      <td>Power Supply</td>
      <td>USB Type-C, 5 V / 1 A</td>
    </tr>

    <tr>
      <td>Data Interface</td>
      <td>RJ45 (Via Adapter), 100BASE-TX</td>
    </tr>

    <tr>
      <td>Glove Connector</td>
      <td>USB Type-C</td>
    </tr>

    <tr>
      <td rowSpan="4">Environment</td>
      <td>Operating Temperature</td>
      <td>-5 \~ 40 °C</td>
    </tr>

    <tr>
      <td>Storage Temperature</td>
      <td>-10 \~ 70 °C</td>
    </tr>

    <tr>
      <td>Operating Humidity</td>
      <td>\< 55% RH</td>
    </tr>

    <tr>
      <td>Storage Humidity</td>
      <td>\< 80% RH</td>
    </tr>
  </tbody>
</table>

<Info>
  * Repeatability test conditions: Glove samples are mounted on a hand mold fixture. Seven distinct zones on the tactile palm surface are selected. A pressure applicator with a 20 mm diameter flat disc probe applies identical force repeatedly to each zone, and the maximum percentage deviation is calculated.
  * Press life / flex life test conditions: Glove samples are worn by a test operator who performs open-grip (to full scale) cycling motions on a cylindrical force measurement device.
</Info>

### EMF specifications

<table>
  <thead>
    <tr>
      <th>Category</th>
      <th>Parameter</th>
      <th>Value</th>
    </tr>
  </thead>

  <tbody>
    <tr>
      <td rowSpan="2">EMF Sensor</td>
      <td>Output Rate</td>
      <td>120 Hz</td>
    </tr>

    <tr>
      <td>Motion-to-Data Latency</td>
      <td>≤ 10 ms</td>
    </tr>

    <tr>
      <td rowSpan="3">Hand Kinematics</td>
      <td>Sensor Distribution</td>
      <td>Thumb, Index, Middle, Ring, Pinky fingertips</td>
    </tr>

    <tr>
      <td>Sensor Data</td>
      <td>3-axis position + 3-axis rotation</td>
    </tr>

    <tr>
      <td>Joint Solving</td>
      <td>Real-time inverse kinematics full-hand solving + joint angles</td>
    </tr>

    <tr>
      <td rowSpan="2">Position Tracking</td>
      <td>External Tracker Mount</td>
      <td>External mechanical interface provided</td>
    </tr>

    <tr>
      <td>Optical Marker Mount</td>
      <td>External mechanical interface provided</td>
    </tr>

    <tr>
      <td rowSpan="2">Environment & Reliability</td>
      <td>Interference Resistance</td>
      <td>Sensitive to metallic/ferromagnetic materials. Keep a clearance of at least 3 cm</td>
    </tr>

    <tr>
      <td>Reliability</td>
      <td>No mechanical wear (sensor body), no electromagnetic hysteresis</td>
    </tr>

    <tr>
      <td rowSpan="3">Calibration</td>
      <td>Calibration Steps</td>
      <td>6-step calibration</td>
    </tr>

    <tr>
      <td>Calibration Goal</td>
      <td>Prioritize accurate joint angles for improved object interaction and gesture recognition</td>
    </tr>

    <tr>
      <td>Optimization Targets</td>
      <td>Bone length, joint pose, fingertip pose</td>
    </tr>
  </tbody>
</table>

## Mechanical Structure

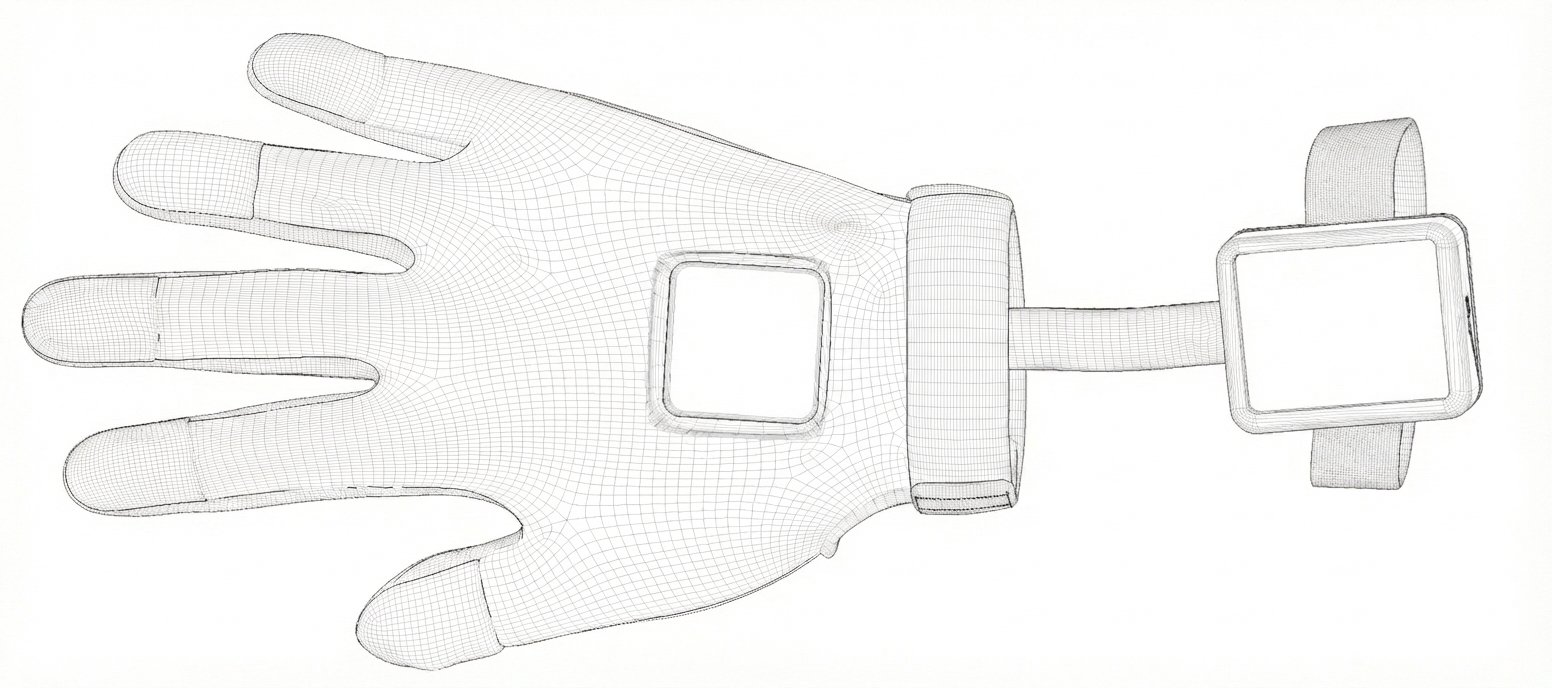
<img src="https://mintcdn.com/wuji-0bbde051/dyEhwe8CJy9DHyJb/assets/source/images/en/wuji-glove/glove-overview.jpg?fit=max&auto=format&n=dyEhwe8CJy9DHyJb&q=85&s=891daf43d0884ff57ff53723b46a13bf" alt="Product Overview" width="1552" height="688" data-path="assets/source/images/en/wuji-glove/glove-overview.jpg" />

<table>
  <thead>
    <tr>
      <th>Component</th>
      <th>Description</th>
    </tr>
  </thead>

  <tbody>
    <tr>
      <td style={{whiteSpace: "nowrap"}}>Glove Palm</td>
      <td><ul><li>Over 500 pressure sensors distributed across the palm form a high-density tactile sensing array.</li><li>Captures and quantifies pressure changes in real time when the palm contacts objects, generating high-resolution hand pressure distribution maps.</li><li>During grasping, provides feedback on the force distribution across different palm regions — from light touch to firm grip, faithfully reproducing the operator's interaction force.</li></ul></td>
    </tr>

    <tr>
      <td style={{whiteSpace: "nowrap"}}>Glove Back</td>
      <td><ul><li>Five EMF modules form a complete hand motion tracking network.</li><li>The five modules are located at the fingertips. Using sensor data from these five key nodes combined with kinematics algorithms, the glove calculates each finger's bending angle, spread amplitude, and the overall spatial pose of the palm.</li></ul></td>
    </tr>

    <tr>
      <td style={{whiteSpace: "nowrap"}}>Data Acquisition Board</td>
      <td>Wire harnesses from the EMF modules extend through a wire protection sleeve to the data acquisition board on the arm. The <a href="#led-status-indicators">indicator LED on the board shows the current glove status</a>.</td>
    </tr>
  </tbody>
</table>

### LED status indicators

Status priority from low to high. Higher-priority states override lower-priority states.

<table>
  <thead>
    <tr>
      <th>Priority</th>
      <th>Indicator</th>
      <th>Color</th>
      <th>Pattern</th>
      <th>Description</th>
    </tr>
  </thead>

  <tbody>
    <tr>
      <td>0</td>

      <td>
        <img src="https://mintcdn.com/wuji-0bbde051/dyEhwe8CJy9DHyJb/assets/source/images/en/wuji-glove/indicator-off.svg?fit=max&auto=format&n=dyEhwe8CJy9DHyJb&q=85&s=d72155ed7dea5b7d5fa90ac3b7cba36d" alt="Off" width="220" height="80" data-path="assets/source/images/en/wuji-glove/indicator-off.svg" />
      </td>

      <td>Off</td>
      <td>Off</td>
      <td>Power off</td>
    </tr>

    <tr>
      <td>15</td>

      <td>
        <img src="https://mintcdn.com/wuji-0bbde051/dyEhwe8CJy9DHyJb/assets/source/images/en/wuji-glove/indicator-cyan-breathing.svg?fit=max&auto=format&n=dyEhwe8CJy9DHyJb&q=85&s=38325595d9a5f82f7b89f551dc8c1408" alt="Cyan breathing" width="220" height="80" data-path="assets/source/images/en/wuji-glove/indicator-cyan-breathing.svg" />
      </td>

      <td>Cyan</td>
      <td>Breathing (4s cycle)</td>
      <td>Standby, waiting for host connection</td>
    </tr>

    <tr>
      <td>20</td>

      <td>
        <img src="https://mintcdn.com/wuji-0bbde051/dyEhwe8CJy9DHyJb/assets/source/images/en/wuji-glove/indicator-cyan-heartbeat.svg?fit=max&auto=format&n=dyEhwe8CJy9DHyJb&q=85&s=00fb6c162ff60038cfd658ad5d2c120b" alt="Cyan heartbeat" width="220" height="80" data-path="assets/source/images/en/wuji-glove/indicator-cyan-heartbeat.svg" />
      </td>

      <td>Cyan</td>
      <td>Heartbeat (50ms on / 1950ms off)</td>
      <td>Normal operation, data streaming</td>
    </tr>

    <tr>
      <td>30</td>

      <td>
        <img src="https://mintcdn.com/wuji-0bbde051/dyEhwe8CJy9DHyJb/assets/source/images/en/wuji-glove/indicator-green-fast-flash.svg?fit=max&auto=format&n=dyEhwe8CJy9DHyJb&q=85&s=7a1e69dc39784637731dec8a005ef6f1" alt="Green fast flash" width="220" height="80" data-path="assets/source/images/en/wuji-glove/indicator-green-fast-flash.svg" />
      </td>

      <td>Green</td>
      <td>Fast flash \~50Hz</td>
      <td>Fatal error: no available firmware</td>
    </tr>

    <tr>
      <td>35</td>

      <td>
        <img src="https://mintcdn.com/wuji-0bbde051/dyEhwe8CJy9DHyJb/assets/source/images/en/wuji-glove/indicator-green-solid.svg?fit=max&auto=format&n=dyEhwe8CJy9DHyJb&q=85&s=63fd88e3fbea42510fe07887d641fb53" alt="Green solid" width="220" height="80" data-path="assets/source/images/en/wuji-glove/indicator-green-solid.svg" />
      </td>

      <td>Green</td>
      <td>Solid</td>
      <td>Self-test / hardware initialization</td>
    </tr>

    <tr>
      <td>40</td>

      <td>
        <img src="https://mintcdn.com/wuji-0bbde051/dyEhwe8CJy9DHyJb/assets/source/images/en/wuji-glove/indicator-blue-fast-flash.svg?fit=max&auto=format&n=dyEhwe8CJy9DHyJb&q=85&s=634b78e453dac3d171813e1408f68d3a" alt="Blue fast flash" width="220" height="80" data-path="assets/source/images/en/wuji-glove/indicator-blue-fast-flash.svg" />
      </td>

      <td>Blue</td>
      <td>Fast flash 2Hz</td>
      <td>Firmware updating</td>
    </tr>

    <tr>
      <td>45</td>

      <td>
        <img src="https://mintcdn.com/wuji-0bbde051/dyEhwe8CJy9DHyJb/assets/source/images/en/wuji-glove/indicator-yellow-very-slow-flash.svg?fit=max&auto=format&n=dyEhwe8CJy9DHyJb&q=85&s=5fc0a255db1b68711df738927f945021" alt="Yellow very slow flash" width="220" height="80" data-path="assets/source/images/en/wuji-glove/indicator-yellow-very-slow-flash.svg" />
      </td>

      <td>Yellow</td>
      <td>Very slow flash 0.5Hz</td>
      <td>Host connected but not pulling data</td>
    </tr>

    <tr>
      <td>50</td>

      <td>
        <img src="https://mintcdn.com/wuji-0bbde051/dyEhwe8CJy9DHyJb/assets/source/images/en/wuji-glove/indicator-yellow-slow-flash.svg?fit=max&auto=format&n=dyEhwe8CJy9DHyJb&q=85&s=047574e4a926a1a4ecde05b19f7759d2" alt="Yellow slow flash" width="220" height="80" data-path="assets/source/images/en/wuji-glove/indicator-yellow-slow-flash.svg" />
      </td>

      <td>Yellow</td>
      <td>Slow flash 1Hz</td>
      <td>Non-critical warning</td>
    </tr>

    <tr>
      <td>90</td>

      <td>
        <img src="https://mintcdn.com/wuji-0bbde051/dyEhwe8CJy9DHyJb/assets/source/images/en/wuji-glove/indicator-red-slow-flash.svg?fit=max&auto=format&n=dyEhwe8CJy9DHyJb&q=85&s=4cb4066a4353b626d1bc9b28d4b5a7bb" alt="Red slow flash" width="220" height="80" data-path="assets/source/images/en/wuji-glove/indicator-red-slow-flash.svg" />
      </td>

      <td>Red</td>
      <td>Slow flash 1Hz</td>
      <td>General software error</td>
    </tr>

    <tr>
      <td>95</td>

      <td>
        <img src="https://mintcdn.com/wuji-0bbde051/dyEhwe8CJy9DHyJb/assets/source/images/en/wuji-glove/indicator-red-fast-flash.svg?fit=max&auto=format&n=dyEhwe8CJy9DHyJb&q=85&s=026ccc6cb0b2362dc10f6256c0c1a38f" alt="Red fast flash" width="220" height="80" data-path="assets/source/images/en/wuji-glove/indicator-red-fast-flash.svg" />
      </td>

      <td>Red</td>
      <td>Fast flash 2Hz</td>
      <td>Ethernet disconnected</td>
    </tr>

    <tr>
      <td>100</td>

      <td>
        <img src="https://mintcdn.com/wuji-0bbde051/dyEhwe8CJy9DHyJb/assets/source/images/en/wuji-glove/indicator-red-solid.svg?fit=max&auto=format&n=dyEhwe8CJy9DHyJb&q=85&s=f1e9390aba2bd0c57e42fdfdb6b16b40" alt="Red solid" width="220" height="80" data-path="assets/source/images/en/wuji-glove/indicator-red-solid.svg" />
      </td>

      <td>Red</td>
      <td>Solid</td>
      <td>Sensor hardware fault</td>
    </tr>
  </tbody>
</table>

## Package Contents

<table>
  <thead>
    <tr>
      <th>Image</th>
      <th>Accessory</th>
      <th>Description</th>
    </tr>
  </thead>

  <tbody>
    <tr>
      <td>
        <img src="https://mintcdn.com/wuji-0bbde051/dyEhwe8CJy9DHyJb/assets/source/images/en/wuji-glove/usb-c-to-usb-c-cable.jpg?fit=max&auto=format&n=dyEhwe8CJy9DHyJb&q=85&s=a52c5bc2244c3ea18292b51616dc4c05" alt="USB-C to USB-C Cable" width="1526" height="678" data-path="assets/source/images/en/wuji-glove/usb-c-to-usb-c-cable.jpg" />
      </td>

      <td style={{whiteSpace: "nowrap"}}>USB-C to USB-C Cable</td>
      <td>Connects the data acquisition board to the USB-C to Ethernet power adapter</td>
    </tr>

    <tr>
      <td>
        <img src="https://mintcdn.com/wuji-0bbde051/dyEhwe8CJy9DHyJb/assets/source/images/en/wuji-glove/usb-c-ethernet-adapter.jpg?fit=max&auto=format&n=dyEhwe8CJy9DHyJb&q=85&s=24aa8f59d73126b700e033619c7b8bd5" alt="USB-C to Ethernet Power Adapter" width="1316" height="1072" data-path="assets/source/images/en/wuji-glove/usb-c-ethernet-adapter.jpg" />
      </td>

      <td style={{whiteSpace: "nowrap"}}>USB-C to Ethernet Power Adapter</td>
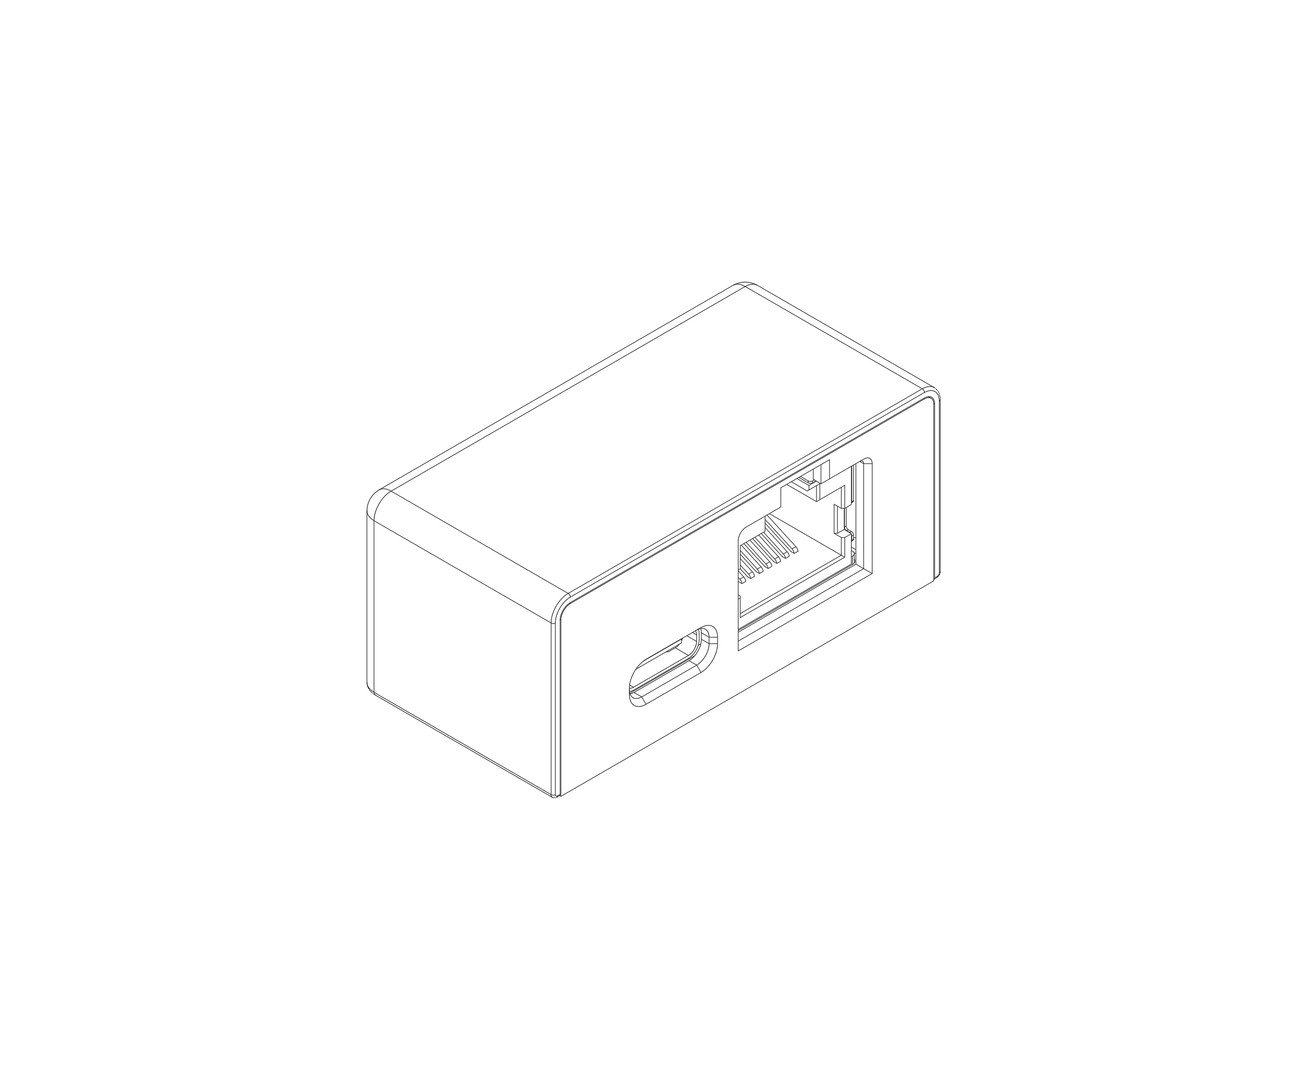
      <td>Powers the glove and provides Ethernet communication</td>
    </tr>

    <tr>
      <td>
        <img src="https://mintcdn.com/wuji-0bbde051/dyEhwe8CJy9DHyJb/assets/source/images/en/wuji-glove/usbatoc.jpg?fit=max&auto=format&n=dyEhwe8CJy9DHyJb&q=85&s=a3b70363a8dc74af6d5337cf785d5c8a" alt="USB-A to USB-C Cable and Ethernet Cable" width="2142" height="666" data-path="assets/source/images/en/wuji-glove/usbatoc.jpg" />
      </td>

      <td style={{whiteSpace: "nowrap"}}><ul><li>USB-A to USB-C Cable</li><li>Ethernet Cable</li></ul></td>
      <td>For subsequent connections via the USB-C to Ethernet power adapter</td>
    </tr>
  </tbody>
</table>

## Software

Access the glove's tactile, EMF, and IMU data through Wuji SDK and Wuji CLI:

| Item | [**Wuji SDK**](/en/docs/wuji-sdk/) | [**Wuji CLI**](/en/docs/wuji-cli/) |
| - | - | - |
| Type | Python and C SDK | Command-line tool |
| Core Capabilities | Real-time tactile data collection, EMF pose data acquisition, IMU data stream, device connection management | Device discovery and connectivity check, real-time visualization, firmware upgrade, hand model calibration and tactile calibration, JSONL data capture |
| System Requirements | Ubuntu 22.04 LTS or later (Python SDK also requires Python 3.10+) | Ubuntu 22.04 LTS or later |

For the glove's tactile, EMF, and IMU data streams and their format definitions, see [SDK Resources](/en/docs/wuji-glove/sdk-data-reference/).


This documentation is built and hosted on [Mintlify](https://mintlify.com), a developer documentation platform.